

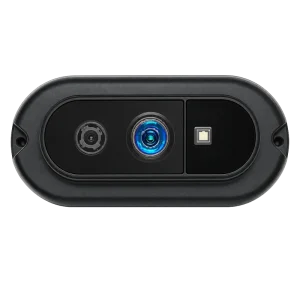
Compare selected RGB-D cameras
DM-RGBD5002A and DM-RGBD5003A are two USB-connected models in our RGB-D portfolio. Use this comparison to explore their specifications and development options.
| Selection factor | DM-RGBD5002A | DM-RGBD5003A |
|---|---|---|
| Depth resolution and frame rate | Up to 640 × 480 at 25 fps | Up to 640 × 480 at 25 fps |
| RGB resolution and frame rate | 1280 × 960 at 30 fps | 1280 × 960 at 30 fps |
| Distance range | 0.2–5 m | 0.2–5 m, indoor / semi-outdoor |
| Depth field of view, H × V | 64° × 51° | 64° × 51° |
| RGB field of view, H × V | 76° × 61° | 76° × 61° |
| Depth accuracy specification | 2% at the center 10 × 10 pixels | ±2% at the center 10 × 10 pixels |
| Host interface | USB 2.0 | USB 2.0 |
| Dimensions | 79 × 35 × 15.7 mm | 79 × 35 × 15.7 mm |
Keep each specification's region and operating conditions with the value. Plan depth and RGB stream settings around the host, selected camera mode and application timing. For object measurement, evaluate the final dimensional tolerance with representative materials, lighting and mounting geometry.
Explore development routes for DM-RGBD5002A and DM-RGBD5003A
DM-RGBD5002A for USB RGB and depth evaluation
The DM-RGBD5002A VGA ToF RGB-D depth camera combines VGA ToF depth and RGB imaging in a compact USB camera. Its development platform options include Windows, Linux, Android and ROS. Use its Rev. 1.0 data sheet and product specifications to start a host and camera configuration discussion around your application.
DM-RGBD5003A for depth maps, point clouds and RGB alignment
The DM-RGBD5003A VGA ToF RGB-D depth camera provides 16-bit raw depth / millimeter distance maps, spatial point clouds and depth–RGB registration / alignment. Its development options include a C/C++ SDK, Python wrapper and ROS 1 / ROS 2 packages, with OpenCV and PCL integration paths.
Match those options to the intended operating system, processor architecture and software version. For color-based processing with depth, plan image calibration, alignment, coordinate conventions, timestamps and concurrent stream modes as part of the acquisition pipeline.
Select an application path
| Application | How color and depth contribute | Evaluation focus |
|---|---|---|
| Robot perception | Color adds visual context to spatial distance samples | Detection zone, target size, motion and complete response timing |
| Machine vision and object inspection | RGB detail and depth geometry provide inputs for object processing | Materials, edge coverage, lighting and the required output |
| 3D reconstruction and measurement | Depth samples support geometric processing alongside color information | Calibration, registration and final measurement tolerance |
Start with our robotics and AMR guide for robot sensing tasks, or the volume measurement guide for parcel and object dimensioning. These paths help connect camera selection to installation and application evaluation.
For an embedded board design using MIPI CSI-2, explore the ToF camera module selection guide to compare module and host-processing routes.
Technical resources and project migration
Download the DM-RGBD5002A datasheet, Rev. 1.0, dated October 10, 2021. The RGB-D calibration guide explains intrinsic parameters, RGB–depth alignment and final assembly checks.
For an existing D435 or D455 project, use our RealSense alternative selection and migration guide to compare camera specifications, mounting and host software work.
FAQs
What resolution and interface do DM-RGBD5002A and DM-RGBD5003A provide?
DM-RGBD5002A and DM-RGBD5003A each provide depth resolution up to 640 × 480 at 25 fps and USB 2.0 host connectivity. Both also provide 1280 × 960 RGB imaging at 30 fps. Choose the stream configuration around your host and application timing.
What are the RGB and depth fields of view of DM-RGBD5002A and DM-RGBD5003A?
DM-RGBD5002A and DM-RGBD5003A each specify a 64° horizontal × 51° vertical depth field of view and a 76° horizontal × 61° vertical RGB field of view. Use these coverage regions and the mounting distance to plan where your task needs color, depth or aligned information.
How should I choose between DM-RGBD5002A and DM-RGBD5003A?
Start with the scene, required output and host software. DM-RGBD5002A offers a USB RGB-D route with a Rev. 1.0 specification reference. DM-RGBD5003A's development route includes depth maps, point clouds, RGB alignment and the named SDK / wrapper options. We can help match the camera configuration to your processing workflow and evaluation goals.
Discuss your RGB-D requirements
Share your application, host platform, working distance, target materials, lighting and required output or measurement tolerance. Discuss your RGB-D camera requirements with our team to plan the camera configuration and evaluation.