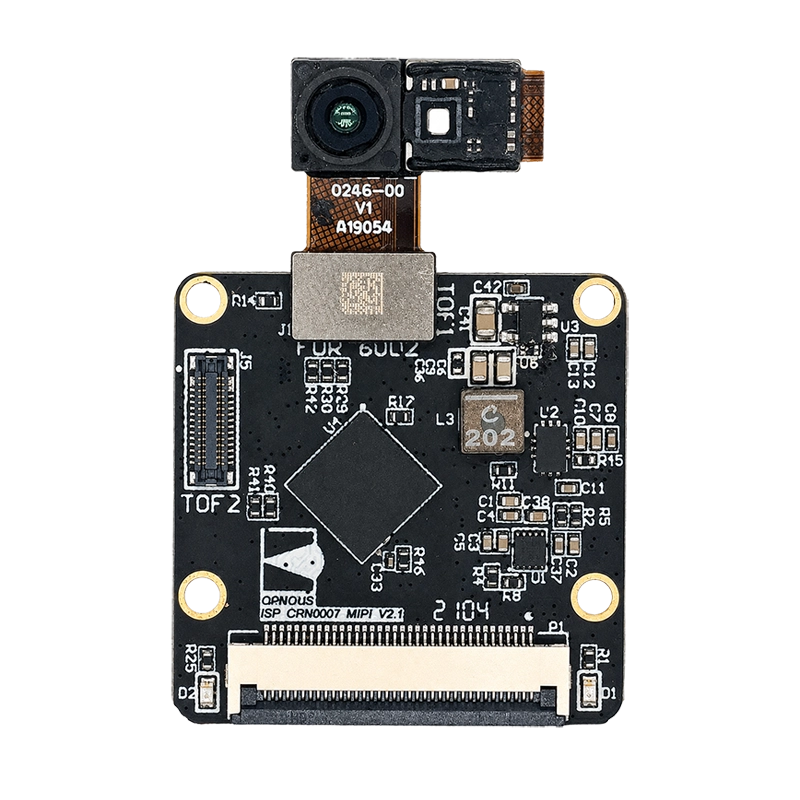
DMOM2501C 100 × 100 Global-Shutter MIPI ToF Depth Module
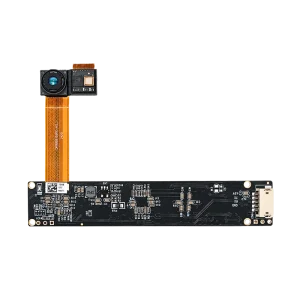
DMOM2501C adds 100 × 100 ToF depth sensing to compact embedded equipment. It combines a global-shutter sensor, 940 nm VCSEL illumination and two-lane MIPI CSI-2 output, with a 44° × 44° field of view and a measurement range up to 6 m.
Key Highlights
- Give embedded perception software a compact depth map from a 100 × 100 global-shutter sensor.
- Plan the observed region around a 44° × 44° field of view and a measurement range up to 6 m.
- Connect the sensing module to your embedded host through two-lane MIPI CSI-2.
- Fit the optical head into a small assembly with a 21.60 × 9.10 × 5.40 mm module envelope.
Overview
DMOM2501C integrates a global-shutter ToF sensor and 940 nm active illumination in a compact optical module. It supplies depth data through two-lane MIPI CSI-2 for designs that incorporate their own receiving electronics and processing software.
The 100 × 100 array and 44° horizontal × 44° vertical field of view provide spatial depth inputs for object sensing, presence interaction and compact robot vision. Typical frame-rate options are 15 and 30 fps, with typical module power consumption of 800 mW at 15 fps.
Its small optical head helps you position depth sensing near a tool, interaction region or object-measurement area. Plan the module position, host capture path and illumination power together as part of the equipment design.
- Resolution
- 100 × 100
- Measurement Range
- Up to 6 m
- Field of View
- 44° H × 44° V
- Data Interface
- MIPI CSI-2, 2 lanes
Applications
Object sensing and measurement
Use the depth map to provide object geometry to detection, dimensioning and volume-measurement software. Choose the mounting position around the object size, observed region and calibration arrangement.
Presence and gesture interaction
Bring spatial depth information into presence and gesture-processing workflows. The 44° × 44° field of view helps define an interaction region within the equipment’s working area.
Robot end-effector vision
Place depth sensing near a gripper or compact tool assembly to supply geometric inputs to the host vision pipeline. The module’s dimensions support integration where mounting space is limited.
Technical Specifications
Sensor and optics
| Parameter | Specification |
|---|---|
| Sensor | Global shutter |
| Depth resolution | 100 × 100 |
| Pixel size | 15 µm |
| Sensor format | 1/6 inch |
| Measurement range | Up to 6 m |
| Frame rate | 15 / 30 fps, typical |
| Field of view | 44° horizontal × 44° vertical |
| Distortion | Less than 2.5% |
| Illumination | 940 nm VCSEL, 3 W |
Host interface, power and dimensions
| Parameter | Specification |
|---|---|
| Data interface | MIPI CSI-2, two lanes |
| Input clock | 27 MHz |
| Sensor supply | 3.3 V; supply capability of at least 300 mA |
| VCSEL supply | 4.6 V; supply capability of at least 2 A |
| Module power consumption | 800 mW typical at 15 fps |
| Module dimensions | 21.60 × 9.10 × 5.40 mm |
Integration
Build the MIPI capture path
Plan the module’s two-lane MIPI CSI-2 connection and 27 MHz input clock with the host receiver and carrier board. Include the capture driver, data handling and application processing in the host workflow.
Plan power and optical placement
Provide separate sensor and VCSEL rails with the specified supply capability. Allow space for the optical head, routing and heat dissipation, and keep the lens and illumination apertures clear of the enclosure.
Use the final cover window and mounting geometry when setting up calibration and checking depth data across your working region. For broader interface choices, explore our ToF camera module range. For a USB host route, compare DM5005A.
FAQs
What depth resolution and frame rates does DMOM2501C provide?
DMOM2501C uses a 100 × 100 global-shutter sensor, with typical frame-rate options of 15 and 30 fps.
What working area does the module cover?
The module has a 44° horizontal × 44° vertical field of view and a measurement range up to 6 m. Use the field of view and target distance to plan the observed region and module position.
How does DMOM2501C connect to an embedded host?
It uses a two-lane MIPI CSI-2 data interface and a 27 MHz input clock. Plan the receiver, carrier board and capture software together for your host platform.
What power supplies does the module require?
The sensor uses a 3.3 V supply with at least 300 mA capability, and the VCSEL uses a 4.6 V supply with at least 2 A capability. Typical module power consumption is 800 mW at 15 fps.
What are the module dimensions?
The optical module measures 21.60 × 9.10 × 5.40 mm. Include clearance for its optical paths and host connection when planning the assembly.
Technical Resources and Evaluation
Share your host processor, target size, working distance, lighting and available mounting space. We can discuss how DMOM2501C fits the capture and integration requirements of your embedded design. Discuss your depth-sensing project with us.
Need help integrating DMOM2501C?
Get expert guidance from our sensing engineers on product selection, evaluation samples, system integration, and technical requirements for your application.
You May Also Like
DMAS2M001
DMOM2508CL
DM5005A