

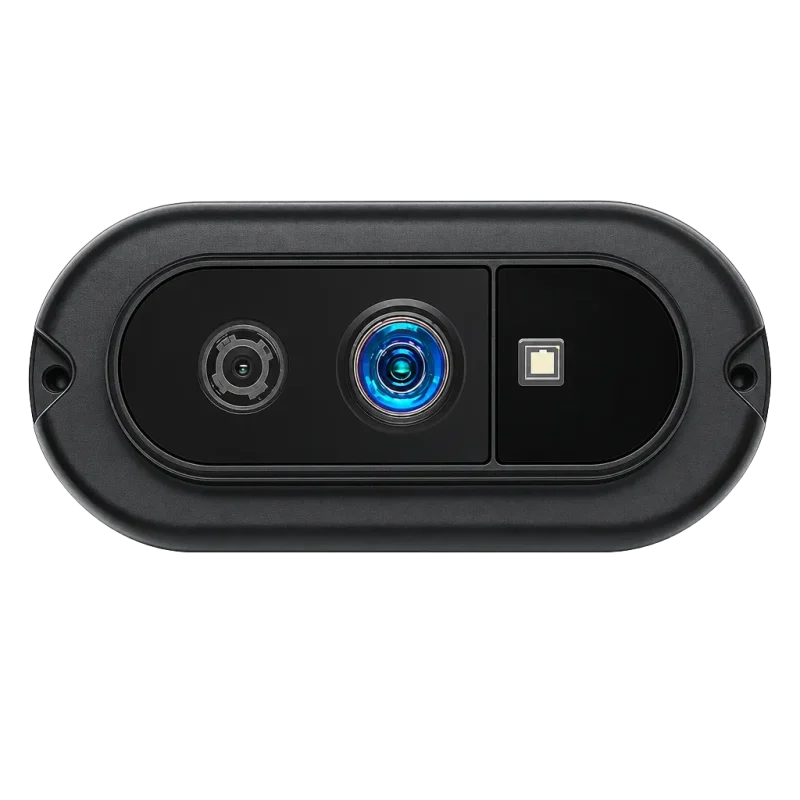
Robot perception: Combine RGB appearance with VGA ToF distance samples and point-cloud geometry as inputs to object and obstacle perception
Depth Resolution
640 × 480 (VGA) @ 25 fps
RGB Resolution
1280 × 960 @ 30 fps
Working Range
0.2–5.0 m
DM-RGBD5003A VGA ToF RGB-D Depth Camera
Bring visual detail and 3D geometry into your robot or machine vision system with DM-RGBD5003A. This compact VGA ToF RGB-D camera combines RGB imaging, depth sensing and point-cloud output to support object perception, spatial measurement and interactive applications.
Key Highlights
- Give your application visual detail and 3D geometry with RGB imaging, VGA ToF depth and point-cloud output.
- Build on your development workflow with C/C++, Python and ROS 1 / ROS 2 integration options.
- Bring nearby objects and workspace geometry into view with depth sensing from 0.2 to 5 m.
- Fit color and depth sensing into your design with USB 2.0 connectivity and a compact 79 × 35 × 15.7 mm housing.
Engineering support
Overview
DM-RGBD5003A gives your vision pipeline RGB images, VGA ToF distance data and X/Y/Z point clouds. Depth–RGB registration connects color information with spatial geometry, allowing your software to use visual appearance and three-dimensional coordinates together when assessing object position, shape and dimensions.
Use its 0.2–5 m working range for indoor and semi-outdoor robot perception, machine vision, volume measurement or gesture interaction. USB 2.0 connectivity and C/C++, Python and ROS 1 / ROS 2 integration options help you bring camera data into your host workflow, with OpenCV and PCL compatibility for image and point-cloud processing.
- Depth Resolution
- 640 × 480 (VGA) @ 25 fps
- RGB Resolution
- 1280 × 960 @ 30 fps
- Working Range
- 0.2–5.0 m
- Interface
- USB 2.0 (Type-C / Micro-B)
Applications
Machine vision: Use RGB detail alongside depth geometry to examine object position, shape and surface orientation
Volume measurement: Use depth and point-cloud coordinates as inputs to calibrated length, width and height measurement
Gesture and AR/VR development: Bring spatial distance and color information into interaction and scene-processing pipelines
Technical Specifications
| Parameter | Specification |
|---|---|
| Depth technology | iToF |
| Depth resolution and frame rate | Up to 640 × 480 at 25 fps |
| RGB resolution and frame rate | 1280 × 960 at 30 fps |
| Distance range | 0.2–5 m, indoor / semi-outdoor |
| Illumination wavelength | 940 nm |
| Depth accuracy | ±2% at the center 10 × 10 pixels |
| Depth field of view | 64° horizontal × 51° vertical |
| RGB field of view | 76° horizontal × 61° vertical |
| Interface | USB 2.0 |
| Depth output | 16-bit raw depth / millimeter distance map |
| RGB output | MJPEG / YUY2 |
| 3D output | Spatial point cloud (X, Y, Z), with depth–RGB registration / alignment |
| Development tools | C/C++ SDK, Python wrapper, ROS 1 / ROS 2 packages; OpenCV and PCL compatibility |
| Power supply | 5 V / 2 A |
| Average power consumption | Less than 3.6 W at 25 fps |
| Dimensions | 79 × 35 × 15.7 mm |
| Operating temperature | −10°C to 45°C |
The ±2% accuracy specification applies to the central 10 × 10-pixel region. For object measurement, plan camera placement and calibration around the dimensions and tolerances your application needs.
Integration Requirements
Hand off RGB-D data to the host
Keep the distance scale, calibration and frame timestamps with each capture. Select a depth-map or point-cloud workflow around the host algorithm, and preserve invalid-data handling during conversion. RGB-depth registration relates color to geometry; the timing of the selected streams belongs in the capture plan.
Before applying a robot-coordinate transform or measuring an object, check the coordinate axes, units and observation time used by the application. Our robot perception guide connects depth data to the host pipeline, and the RGB-D guide explains color-depth correspondence.
Choose the data your application needs. VGA ToF depth maps provide up to 640 × 480 spatial distance samples, RGB images add visual detail, and X/Y/Z point clouds provide three-dimensional coordinates for geometric processing. Depth–RGB registration lets you relate color information to depth geometry.
Our development options include C/C++, a Python wrapper, ROS 1 / ROS 2 packages, and OpenCV and PCL compatibility. Tell us your host platform and framework so we can discuss the package and configuration for your project. For moving scenes, include stream timing and calibration in the integration plan.
FAQs
What depth detail and coverage does DM-RGBD5003A provide?
DM-RGBD5003A provides VGA ToF depth up to 640 × 480 at 25 fps, with a 64° horizontal × 51° vertical depth field of view. Its 0.2–5 m range covers indoor and semi-outdoor tasks from nearby object perception to workspace measurement.
What data can I use from DM-RGBD5003A?
DM-RGBD5003A offers 16-bit raw depth or millimeter distance maps, MJPEG / YUY2 RGB images, and X/Y/Z point-cloud output. Use depth–RGB registration to connect color information with three-dimensional geometry in your processing pipeline.
How can I connect DM-RGBD5003A to my development tools?
We offer C/C++, Python and ROS 1 / ROS 2 integration options, with OpenCV and PCL compatibility. Share your host platform and framework with us to discuss the software configuration for your project.
How should I choose between DM-RGBD5003A and DM-RGBD5002A?
Start with the data outputs and development tools your project uses, then compare working distance, field of view and host integration in our RGB-D camera selection guide. For DM-RGBD5003A, depth maps, RGB images, registered point clouds and ROS integration provide specific routes into a vision pipeline. Share your requirements with us to discuss the model and configuration.
Technical Resources and Evaluation
Compare DM-RGBD5002A for another USB RGB-D configuration. For a board-level host design, review the ToF camera module selection guide.
Discuss your VGA ToF RGB-D application with us. Share your host platform, required working region, target materials, lighting and measurement goals to discuss a DM-RGBD5003A configuration and software resources for your project.
Need help integrating DM-RGBD5003A?
Get expert guidance from our sensing engineers on product selection, evaluation samples, system integration, and technical requirements for your application.
You May Also Like
DM-RGBD5002A
Depth Resolution
640 × 480 (VGA) @ 25 fps
RGB Resolution
1280 × 960 @ 30 fps
Working Range
0.2–5.0 m
Interface
USB 2.0