

No RGB capture
Depth geometry can reduce identification risk, but the full data path still needs governance.
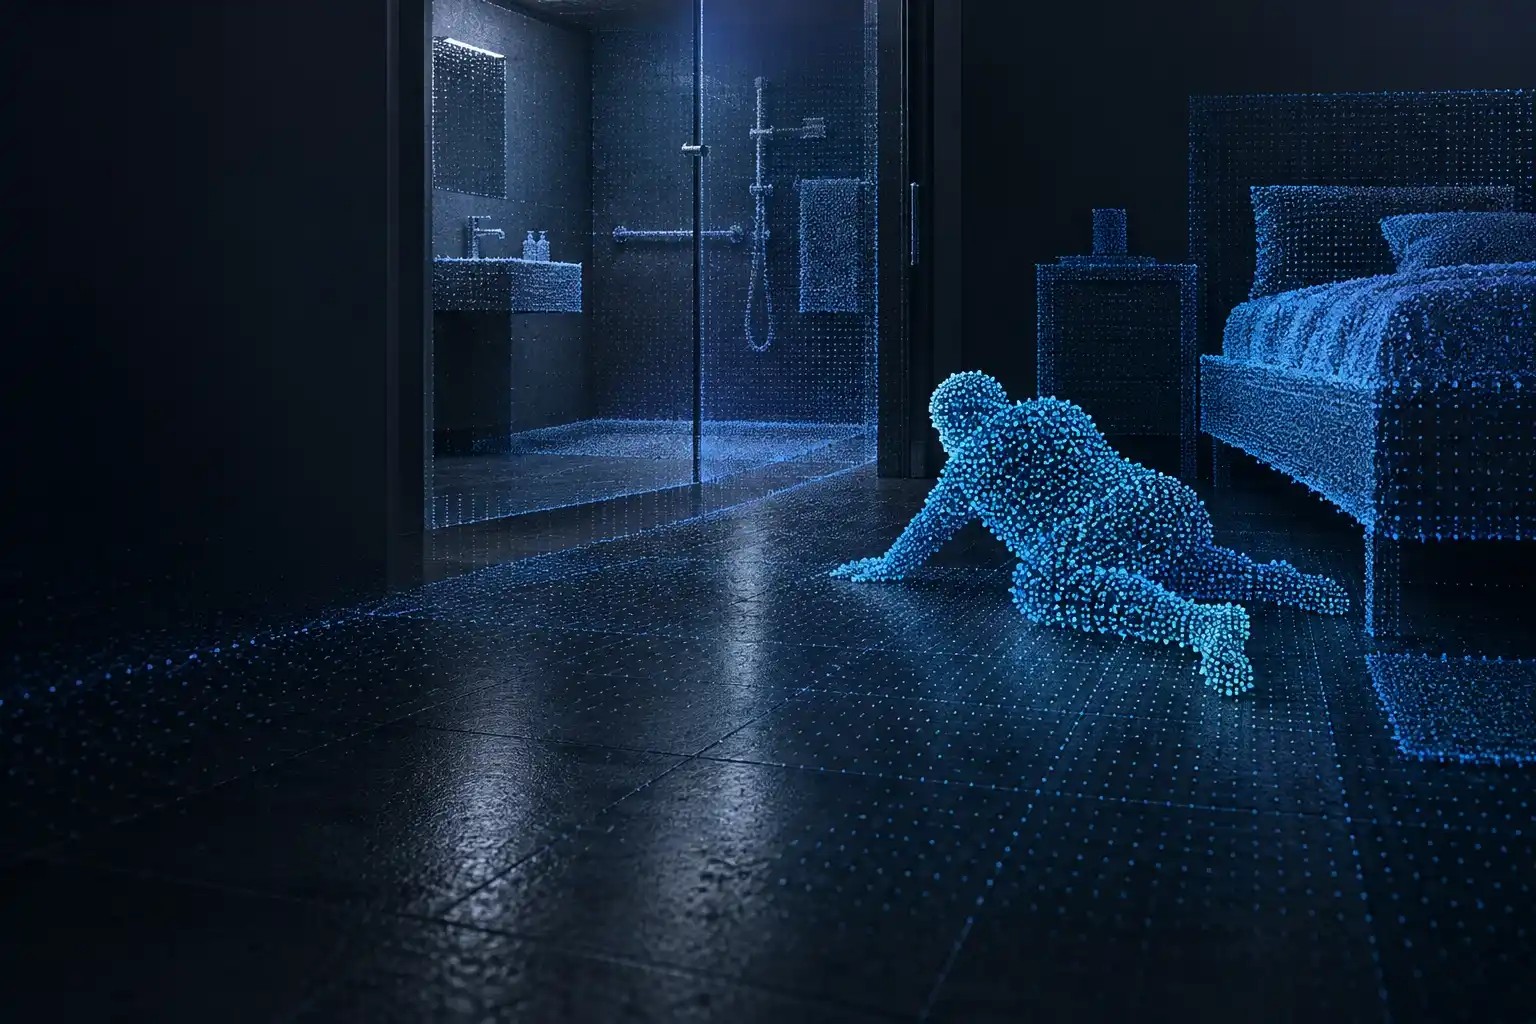
Build privacy-first fall detection for bathrooms and bedrooms using depth-only 3D geometry, edge processing and application-specific validation.
Plan My EvaluationWhy depth geometry
3D ToF generates geometric distance data rather than RGB video. The host can analyze posture, floor boundaries and room context in real time while reducing the privacy surface in bathrooms and bedrooms.
Depth geometry can reduce identification risk, but the full data path still needs governance.
Active near-infrared sensing does not depend on a lit room. Materials and optical conditions still matter.
Keep raw frames local and send only the event fields the product actually needs.
Qualify the room before choosing a module. The useful signal is the relationship between a person, the floor, the bed and the surrounding furniture.
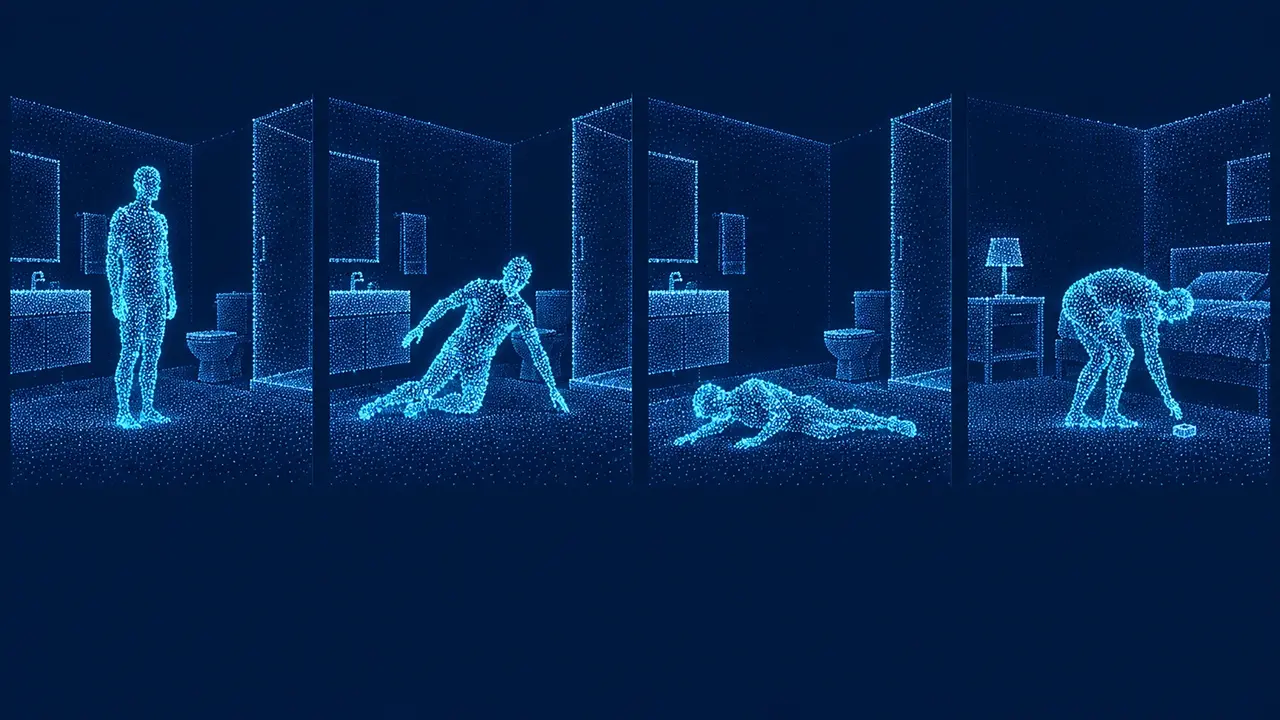
Assess slips, slow collapses, long low-position events and recovery near the toilet, shower or wet floor.
Separate bed height, floor height, bedside sliding and fast movement onto a mattress with room geometry.
Include walkers, carers, partial occlusion and more than one person in the data and acceptance plan.
Compare another sensing mode when persistent steam, no direct line of sight, through-wall sensing or vital signs are central requirements.
The module is one layer in the product. Make the sensing, perception and data handoffs explicit so engineering and privacy reviews can follow the evidence.
The emitter sends modulated light into the scene.
The sensor estimates distance for each valid pixel.
The frame carries depth, signal quality and invalid flags.
The host can derive point clouds, planes and posture features.
Application logic evaluates a sequence, not one low-height frame.
Use locally for segmentation, calibration and scene validation. Default path: no upstream storage.
Use posture, plane distance, trajectory and confidence features where the application needs them.
Send only the room or device ID, time, event type and confidence required by the customer system.
No RGB does not mean no data governance. Define whether IR intensity, raw depth, derived pose and event data are enabled, stored, transmitted and accessible.
Architecture + wavelength
Area-array iToF is usually the stronger first evaluation for dense posture and floor geometry. Compare SPAD dToF, 850 nm or another sensing mode when scattering, range, steam or hidden mounting dominates.
| Route | What it observes | Qualification question |
|---|---|---|
| 3D ToF depth | Dense depth map or point cloud for body, floor, bed and furniture geometry. | Strong starting point for posture boundaries and explainable room geometry. Validate steam, mirrors, MPI and occlusion. |
| 60 or 77 GHz mmWave | Range, velocity and angle data with motion and micro-motion potential. | Compare when persistent steam, optical occlusion or hidden mounting is central. Validate multipath and ghost targets. |
| Thermal imaging | Two-dimensional temperature distribution and human heat silhouette. | Consider when temperature contrast and cost fit the project. Validate reflections, ambient heat and occlusion. |
| PIR or sensor fusion | Low-detail occupancy trigger, or complementary coverage for independent failure modes. | Useful as a wake-up or fusion input, but test slow collapses, pets, HVAC movement and room-level blind spots. |
A practical first comparison for bedrooms, bedside zones and near-range bathrooms. Verify ambient-light margin, detector response and the complete IEC 60825-1 Class 1 system path.
Consider it when ceiling mounting needs longer reach or wider coverage. Treat visible glow, resident comfort, ambient response and eye-safety margins as acceptance criteria.
The optical-axis pitch angle, diagonal distance, pixel coverage, emitter drive, cover window and host compute budget should be evaluated as one design. No iToF or dToF label removes the need for scene testing.
A credible fall event combines motion, posture, support planes, duration, confidence and recovery. Steam, condensation, wet windows, mirrors and glossy tiles can also create ambiguous depth.
Record valid-depth coverage, range bias and track continuity before water or steam is introduced.
Measure temperature, humidity and optical-window conditions as the room becomes wet and warm.
Check confidence, invalid pixels, false clusters and behavior across the target mounting angle.
Record wet-window behavior after water stops and define a visible degraded mode.
Monitor valid-depth coverage, distance bias, signal strength, confidence, false clusters, track interruptions and recovery time. Define degraded mode instead of silently accepting bad output.
Datasheet-based shortlist
Start with room range, field of view, frame rate and host interface. These candidates support evaluation; the final choice still depends on enclosure, condensation, EMC and acceptance testing.
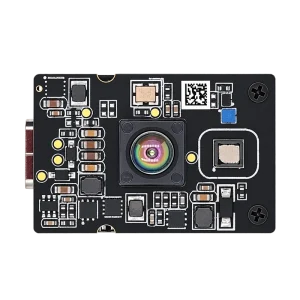
Compact SPAD dToF path
Compare when time gating, scattering or range separation dominates.
View product details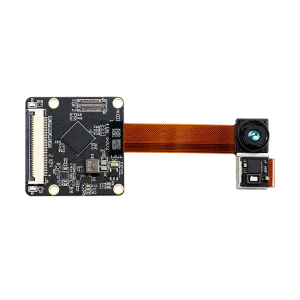
Compact embedded path
Start here for near-range or lower wall mounting.
View product details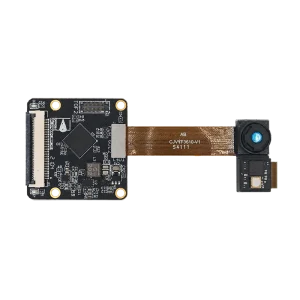
Mid-range embedded path
Consider for ceiling mounting and larger bedrooms.
View product details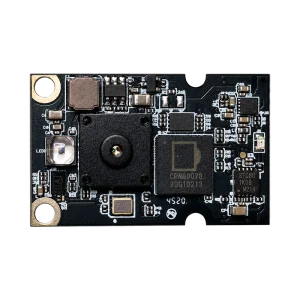
Low-data wide field of view
Consider when lower bandwidth supports data minimization.
View product detailsIP rating, condensation, disinfectant exposure, optical window and EMC remain customer-system validation items.
Direct answers to the privacy, environment, algorithm and module questions that shape an evaluation brief.
Plan My EvaluationDepth-only 3D ToF does not capture RGB color or facial texture, which materially reduces identification risk. Privacy still depends on the complete system: process frames locally, transmit only necessary event data, restrict raw-depth retention, control access and assess whether the remaining data can be linked to an individual.
3D ToF is often the better starting point when the algorithm needs dense body geometry, floor distance, posture boundaries and room context. mmWave is often stronger under persistent steam, optical occlusion or when micro-motion is required. The correct choice depends on mounting, materials, privacy architecture and validation data.
Visible darkness is not the main limitation because ToF uses active near-infrared illumination. Steam, condensation, wet optical windows, glossy tiles and mirrors can still reduce signal or produce invalid and multipath depth. Qualification must measure valid-depth coverage, range bias, false clusters and recovery after condensation.
It can provide useful features for that distinction, including centroid height and velocity, body axis, support-plane distance, contact area, trajectory continuity, low-position duration and recovery. The customer or algorithm partner still needs scene-specific data and acceptance criteria.
A depth system can model bed height, floor height and the body relationship to each support plane. Bed geometry, occlusion, bedding and mounting angle still require direct validation, especially for fast movement onto a mattress.
DOMI provides depth modules, data outputs, SDK and reference integration support. The final fall classifier, data set, thresholds, alert policy and product validation remain with the customer or its algorithm partner unless a separate scope defines otherwise.
DMOM2808D is a candidate for mid-range embedded evaluation with a published 0.25-4.5 m range and 71.8 x 56.5 degree field of view. The correct choice still depends on the actual diagonal distance, pixel coverage, wavelength, ambient light, enclosure and validation results.
Do not infer an IP or condensation rating from the module name. The enclosure, optical window, seals, cleaning process, thermal design and final EMC and ingress tests belong to the customer system qualification.
BAA applicability depends on whether DOMI or its service processes protected health information on behalf of a regulated entity. A hardware supplier that does not receive or maintain that data should not claim BAA status by default. Review the actual data flow and contract roles.
The architecture can be designed so raw depth is processed locally and not sent upstream. Confirm whether IR intensity, diagnostic frames, derived pose or event history are also enabled, stored or exposed by the final product.
Collect representative room geometry, mounting positions, lighting, steam, condensation, mirrors, wet surfaces, occlusion, daily actions, fall types, people variation, network faults and recovery behavior. Report recall, precision, false alarms, latency and sensor-health indicators by condition.
Plan your evaluation
Share your room geometry, operating conditions and integration path. We will help shortlist the sensor, identify validation risks and define the next engineering test.
A few details are enough to start the conversation. Add dimensions, mounting height or host-platform details if they are available.