Face sensing and spatial HMI
- Face recognition and face motion tracking
- Hand and finger tracking for gesture control
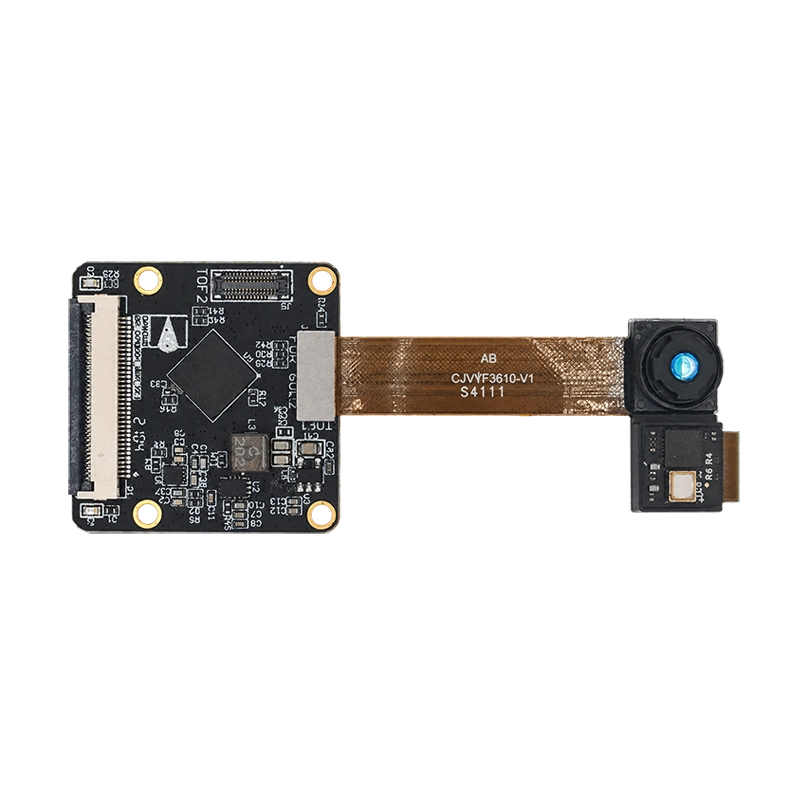
Compact 320 × 240 depth module with 850 nm VCSEL illumination, 0.25-4.5 m range and 2-lane MIPI CSI-2 output.
Key Highlights
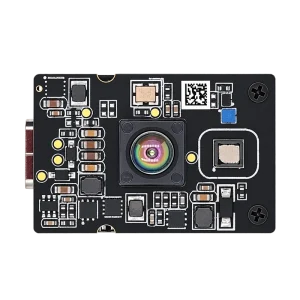
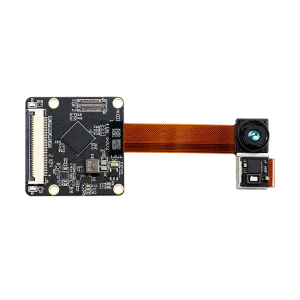
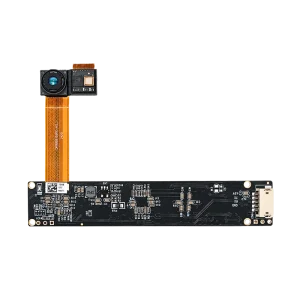
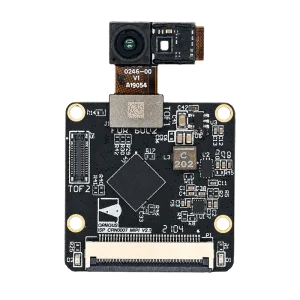
The DOMI DMOM2808D is a compact 3D Time-of-Flight camera module that combines a 320 × 240 global-shutter sensor with 850 nm, 2 W VCSEL illumination. DMOM2808D supports a 0.25-4.5 m measurement range, 10-30 fps frame rate and a 71.8° horizontal × 56.5° vertical field of view.
With a module head measuring 21.00 × 9.50 × 6.33 mm and a 2-lane MIPI CSI-2 output, DMOM2808D is designed for space-constrained embedded depth sensing. The interface also exposes SPI, I2C CCI, synchronization, reset and error signals through a 30-pin connector.
DMOM2808D specifies depth accuracy of ≤1% / ≤1 cm (Rev 1.0) and distortion below 2.5%. Evaluate performance with the final optical stack, ambient light, target reflectivity, temperature and multi-camera environment.
DMOM2808D combines 320 × 240 depth sensing, 850 nm illumination and a specified 0.25-4.5 m range for embedded designs. For a near-field design using 940 nm illumination, compare DMOM2508CL, which specifies 0.2-2 m. Both use 2-lane MIPI CSI-2; select the module around the required distance, optical design, power rails and host pipeline. Our ToF camera module selection guide explains the available integration routes.
DMOM2808D is intended for embedded systems that need real-time depth information in a compact optical module.
| Parameter | Specification |
|---|---|
| Sensor | Global shutter |
| Resolution | 320 × 240 |
| Pixel size | 15 µm |
| Sensor size | 1/3 inch |
| Module dimensions | 21.00 × 9.50 × 6.33 mm |
| Frame rate | 10-30 fps |
| Measurement range | 0.25-4.5 m |
| Field of view | 71.8° horizontal × 56.5° vertical |
| Distortion | <2.5% |
| Illumination | 850 nm, 2 W VCSEL |
| Input clock | 27 MHz |
| Power supply | Sensor: 3.3 V single supply, ≥300 mA VCSEL: 4.6 V, ≥2 A |
| Power consumption | 340 mW typical |
| Depth accuracy | ≤1% / ≤1 cm |
| Data interface | MIPI CSI-2, 2 lanes |
Plan reference measurements across the target materials, distances and lighting in your application. Record the module configuration, temperature and optical assembly alongside depth error and valid-data coverage.
Share your host processor, required output, working distance, target materials, lighting and mounting arrangement with us. These details help define the capture, processing and mechanical work for your evaluation. Include the final cover window and enclosure when checking depth accuracy, calibration and valid-data coverage.
Plan the sensor’s 3.3 V rail and the VCSEL’s 4.6 V rail with the current capability specified above. Evaluate startup, transient current, heat dissipation and optical performance in the assembled device.
Yes. The module integrates an 850 nm, 2 W VCSEL illuminator with the ToF sensor for active depth sensing.
DMOM2808D provides 320 × 240 depth resolution with a specified frame-rate range of 10-30 fps.
The datasheet specifies a 0.25-4.5 m measurement range and a 71.8° horizontal × 56.5° vertical field of view.
Yes. It uses a 2-lane MIPI CSI-2 data interface and also exposes SPI, I2C CCI, synchronization, reset and error signals on its 30-pin connector.
Yes. The datasheet lists hand and finger tracking, gesture control, interaction with virtual objects and AR/VR among its typical applications.
Yes. Typical applications include visual support for robot grippers, localization and tracking, people counting and motion analysis. System performance still needs validation in the final scene.
The sensor requires a 3.3 V single supply rated for at least 300 mA. The VCSEL rail requires 4.6 V rated for at least 2 A.
The module connector is AXE630124, and the mating connector specified in the datasheet is AXE530127.
Get expert guidance from our sensing engineers on product selection, evaluation samples, system integration, and technical requirements for your application.