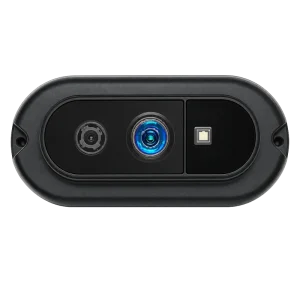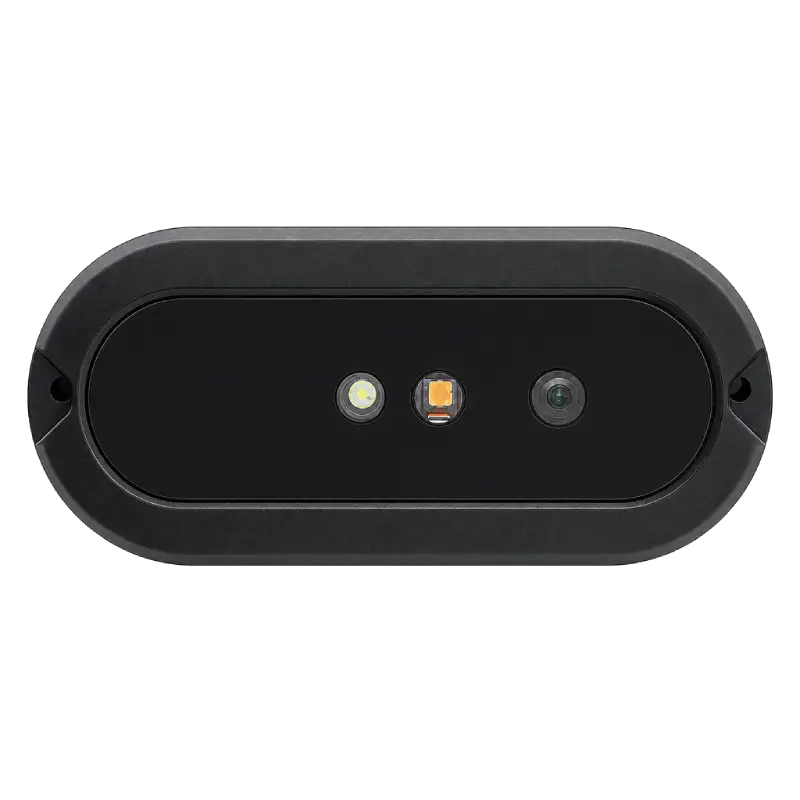
DM-RGBD5002A VGA ToF RGB-D Depth Camera
DM-RGBD5002A brings color images and depth information into a USB-connected vision system. It combines ToF resolution up to 640 × 480 at 25 fps with 1280 × 960 RGB imaging at 30 fps and a 0.2-5 m distance range. Use the two types of information in host software for robot perception, 3D reconstruction or object measurement.
Key Highlights
- Give your vision pipeline visual appearance and distance information with RGB and VGA ToF sensing in one camera.
- Plan close-up and wider-workspace capture around a 0.2-5 m distance range.
- Connect color and depth sensing to the host through USB 2.0.
- Fit RGB-D capture into your equipment with a 79 × 35 × 15.7 mm camera body.
Overview
DM-RGBD5002A pairs a 940 nm ToF sensing path with RGB imaging. Color provides visual detail, while depth provides geometric input for the host’s perception or measurement task.
The ToF field of view is 64° horizontal × 51° vertical; the RGB field of view is 76° horizontal × 61° vertical. Use both when positioning the camera around a shared working region. For applications combining the streams, include calibration, registration and frame timing in the host integration plan.
- Depth Resolution
- 640 × 480 (VGA) @ 25 fps
- RGB Resolution
- 1280 × 960 @ 30 fps
- Working Range
- 0.2–5.0 m
- Interface
- USB 2.0
Applications
Robot perception
Use RGB appearance and depth geometry as inputs for the robot’s object and scene analysis. Match camera placement to the target region and the host software’s processing path. Our 3D obstacle-avoidance guide connects sensing input to robot perception tasks.
3D reconstruction and object measurement
Depth measurements provide geometric samples, with RGB images supplying appearance information for the reconstruction workflow. For object measurement, choose placement and calibration around the required object coverage and dimensional tolerance. See the volume-measurement guide for application planning.
Face capture and spatial interaction
RGB and depth provide complementary inputs for host-side face acquisition and AR/VR software. Our face-system guide explains camera capture, liveness processing and authentication as parts of the application architecture.
Technical specifications
| Parameter | Specification |
|---|---|
| ToF resolution and frame rate | Up to 640 × 480 at 25 fps |
| RGB resolution and frame rate | 1280 × 960 at 30 fps |
| Distance range | 0.2-5 m |
| Illumination wavelength | 940 nm |
| Depth accuracy | 2% in the central 10 × 10-pixel region |
| ToF field of view | 64° horizontal × 51° vertical |
| RGB field of view | 76° horizontal × 61° vertical |
| Interface | USB 2.0 |
| Supply | 5 V / 2 A through USB 2.0 |
| Average power consumption | <3.6 W at 25 fps |
| Dimensions | 79 × 35 × 15.7 mm |
| Operating temperature | -10 to 45 °C |
| Software platform options | Windows, Linux, Android and ROS |
Host and capture integration
USB and software
Provide the 5 V / 2 A USB supply and choose the software configuration around the host platform. DM-RGBD5002A supports Windows, Linux, Android and ROS. We can help match the camera’s data and software resources to the application framework.
RGB-D calibration and timing
Use the RGB and ToF fields of view to define the common capture region. Plan image registration and the timing of each stream around the host software, especially when the subject moves. Our RGB-D calibration guide covers reference captures and installed-camera validation.
The 2% depth-accuracy specification applies to the central 10 × 10-pixel region. Use that region with the figure when selecting the reference measurements for your application.
Technical resources
Download the DM-RGBD5002A datasheet, Rev. 1.0. To compare model specifications and host routes, see our RGB-D camera selection guide and DM-RGBD5003A.
FAQs
What RGB and depth streams does DM-RGBD5002A provide?
ToF resolution reaches up to 640 × 480 at 25 fps. RGB resolution is 1280 × 960 at 30 fps. Use the relevant stream specifications when planning the host data path and capture timing.
What depth-accuracy region does the specification cover?
Depth accuracy is 2% in the central 10 × 10-pixel region.
What fields of view should I use for placement?
The ToF field of view is 64° horizontal × 51° vertical, and the RGB field of view is 76° horizontal × 61° vertical. Use both to plan the working region for combined color and depth capture.
How should I choose between DM-RGBD5002A and DM-RGBD5003A?
Compare each model’s specifications and integration options in the RGB-D camera selection guide. The required streams, host software and application geometry provide the starting points for model selection.
Discuss your RGB-D application
Tell us the host platform, working distance, target objects and required measurement tolerance. We can help plan the DM-RGBD5002A capture configuration and software path for your project.
Need help integrating DM-RGBD5002A?
Get expert guidance from our sensing engineers on product selection, evaluation samples, system integration, and technical requirements for your application.
You May Also Like