AR/VR and gesture interaction
- Hand and finger tracking for gesture control
- Interaction with virtual objects and spatial user interfaces
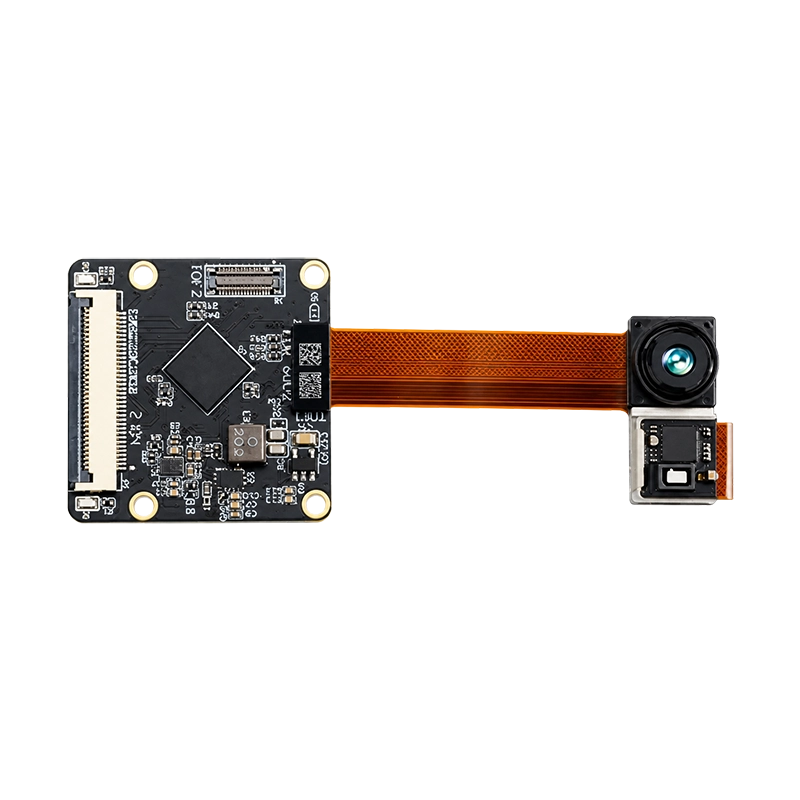
A compact 940 nm ToF camera module for near-field depth sensing in AR/VR, gesture, robotics and people-analysis systems.
Key Highlights
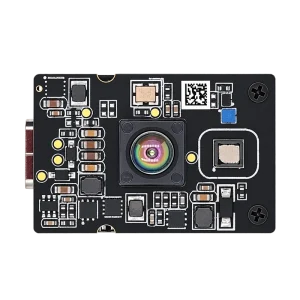
DMOM2508CL is a compact 320 × 240 Time-of-Flight depth camera module for embedded spatial sensing. It combines a global-shutter sensor, 940 nm active illumination and a 2-lane MIPI CSI-2 interface for applications that need near-field depth data rather than RGB imagery alone.
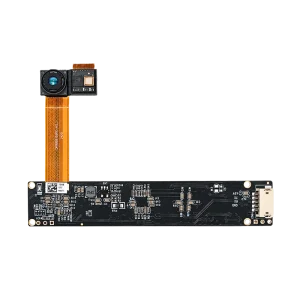
The published specification lists a 0.2-2 m measurement range, 10-30 fps operation, 71.8° horizontal × 56.6° vertical field of view and a 21.00 × 9.50 × 6.33 mm module head. These parameters make the module a practical starting point for space-constrained AR/VR, gesture, robotics and people-analysis designs.
The stated depth accuracy is ≤1% or ≤1 cm, with distortion below 2.5%. The source does not publish the distance, target reflectivity, ambient illumination or temperature used for these figures. Validate depth performance after integrating the final optical window, enclosure and host platform.
DMOM2508CL is intended for compact products that use depth maps for interaction, measurement or scene awareness.
| Parameter | Published specification |
|---|---|
| Sensor type | Global shutter |
| Depth resolution | 320 × 240 |
| Pixel size | 15 µm |
| Sensor size | 1/3 inch |
| Measurement range | 0.2-2 m |
| Field of view | 71.8° horizontal × 56.6° vertical |
| Distortion | <2.5% |
| Depth accuracy | ≤1% or ≤1 cm |
| Parameter | Published specification |
|---|---|
| Frame rate | 10-30 fps |
| Illumination | 940 nm, 3 W |
| Input clock | 27 MHz |
| Power consumption | 340 mW typical |
| Parameter | Published specification |
|---|---|
| Data interface | MIPI CSI-2, 2 lanes |
| Sensor supply | 3.3 V single supply, ≥300 mA |
| VCSEL supply | 4 V, ≥2 A |
| Module dimensions | 21.00 × 9.50 × 6.33 mm |
FAE note: The source lists 340 mW typical power consumption and separately specifies sensor and VCSEL supply requirements. Confirm the complete rail budget, peak current, sequencing, ripple and thermal behavior with the latest integration documentation before design release.
The published page does not specify host processor compatibility, supported SDK or operating systems, laser safety class, IP rating, operating-temperature range, calibration flow or ambient-light immunity. Request the latest datasheet and integration guidance for production qualification.
Yes. DMOM2508CL is specified with 320 × 240 depth resolution and a global-shutter sensor.
The published measurement range is 0.2-2 m. Final usable range depends on the optical stack, target reflectivity, ambient light and application conditions.
Yes. DMOM2508CL provides a 2-lane MIPI CSI-2 data interface. Confirm receiver compatibility, lane routing, timing and host-driver support on the target platform.
Yes. AR/VR interaction, hand and finger tracking, and gesture control are listed application directions for DMOM2508CL. Validate tracking performance in the final user volume and lighting environment.
Yes. The published specification lists 940 nm, 3 W illumination for active depth sensing. The complete end product still requires laser-safety and compliance validation.
DMOM2508CL is specified for 10-30 fps operation. The delivered system frame rate can depend on host bandwidth, depth-processing pipeline and configuration.
The sensor requires a 3.3 V single supply rated for at least 300 mA. The VCSEL rail is specified as 4 V rated for at least 2 A.
The module head measures 21.00 × 9.50 × 6.33 mm. Its specified field of view is 71.8° horizontal × 56.6° vertical.
Get expert guidance from our sensing engineers on product selection, evaluation samples, system integration, and technical requirements for your application.