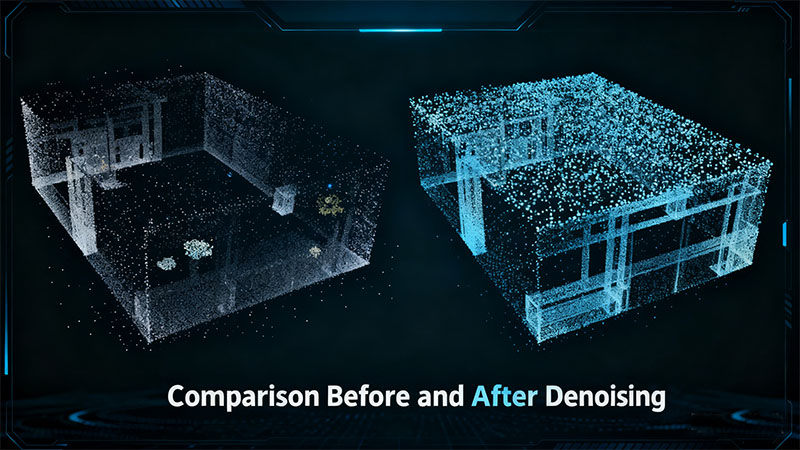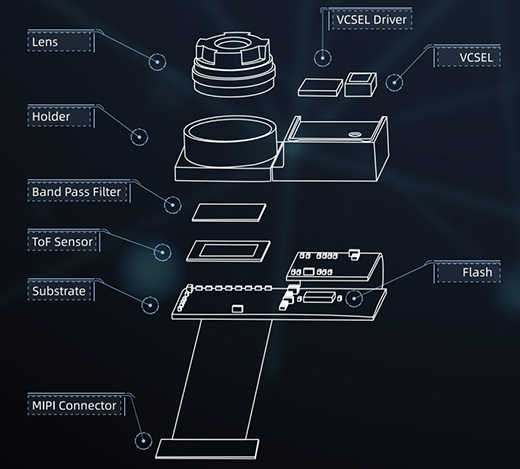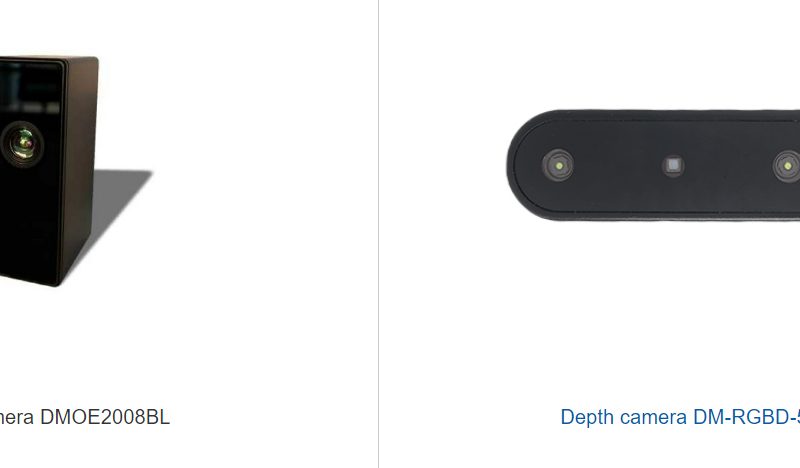
ToF sensing can support many products, but broad application lists are useful only when they connect a measurement to a task. A sensor that reports one distance, a multi-zone module, and a depth camera are not interchangeable. Select a current product for a defined operating range, output, and environment.
Match the output to the use case
- Presence or approach: a single distance or zone can trigger an appliance or detect an object in a specified region.
- Robotics: several ranges or a depth map can support obstacle localization and mapping; control software handles recognition and motion.
- Industrial sorting: spatial depth can contribute to parcel segmentation, dimensioning, and grasp planning after calibration.
- Commercial spaces: a configured overhead depth view can support movement counts or occupancy estimates, subject to validation and privacy design.
Questions before choosing a module
What is the required distance at the darkest and brightest expected target? How much of the scene must be visible? What error and missing-return rate can the application tolerate? What are the power, update-rate, enclosure, and interface constraints? Which parts of the function require software beyond the sensor?
Earlier articles listed broad use cases and several historical module names. Those examples describe possible applications, not evidence that a particular current module meets their range, accuracy, safety, or deployment claims. Use the latest product documentation and a representative test setup for model selection.